
Buying Slip Rings and Rotary Unions for Robots: Power Across Continuous Rotation
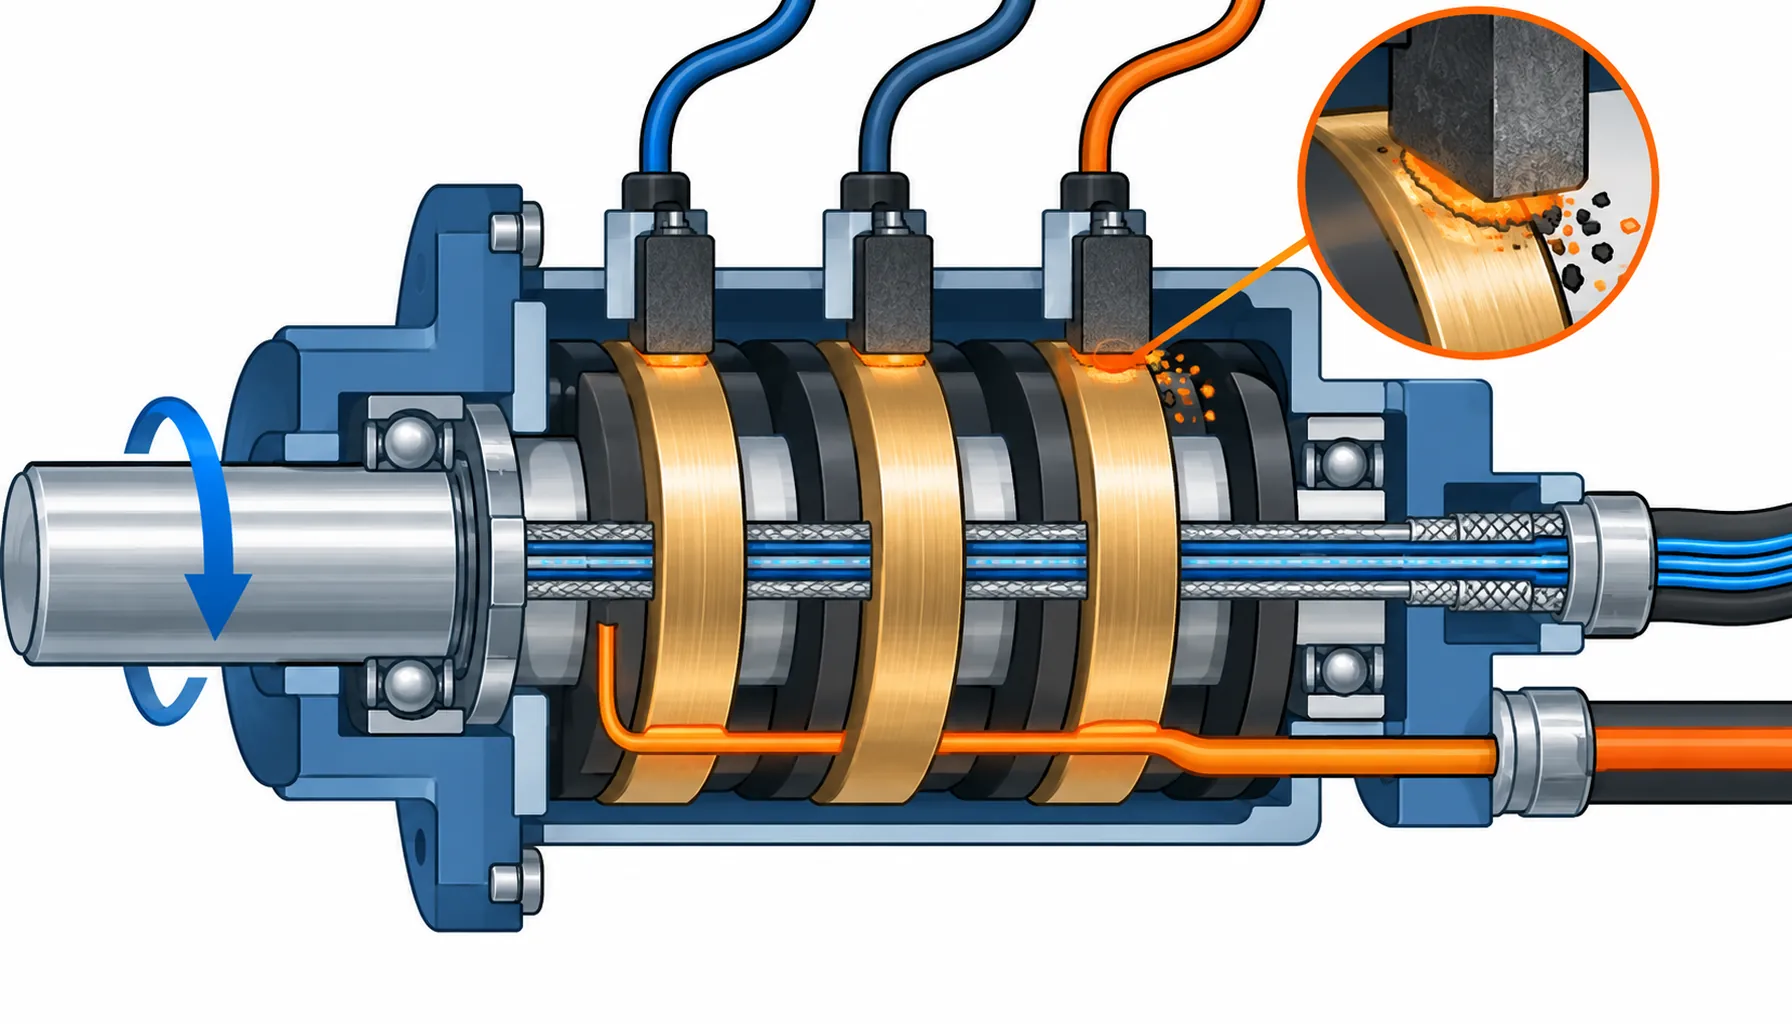
Quick Answer: When an axis turns without a hard stop, no cable survives, so the cable has to be replaced by a rotating transfer. Slip rings carry power and signal across the turning joint, rotary unions carry air or fluid, and contactless couplings do both without touching. Each has a wear mechanism, a maintenance interval and a failure mode, and the purchase decision is really about which circuit needs which transfer, how much noise the signal can tolerate, and whether a cheaper limited-sweep cable would be enough if the axis only ever turns part of a revolution.
Introduction
Most robot axes sweep back and forth and never complete a turn, which is why flexible cable solves most of the problem. The exceptions are real, though: a turntable, a rotating camera head, a continuous-process tool or a wrist that indexes all the way round. On those axes a cable will wind up and fail no matter how flexible it is, and the design has to pass power and signal through a rotating joint instead.
The routing that comes just before this decision is covered in our notes on cable routing through robot joints and on hollow shaft cable routing. This guide takes over at the point where routing stops working: what a rotating transfer is, how the main types differ, and what to freeze at order time.
Why Continuous Rotation Kills Cable
A flexible cable is built to bend and, in a torsion rated version, to twist through a limited angle. A full rotation is a different duty. Each turn adds to the twist until the bundle has wound itself into a spiral, the conductors are pulled against their lay direction, and the screen opens at the point where the accumulated twist is worst. There is no jacket that prevents it, because the failure is structural rather than a matter of surface wear.
The practical rule is simple. If an axis turns past a full revolution, or indexes in the same direction again and again, the cable has to be replaced by a rotating transfer, with short fixed cables on each side of it. Where an axis only sweeps within a limited angle, a properly rated torsion cable can still be the cheaper answer, and the constructions for that duty are set out in our note on torsion cable construction.
The Five Ways to Cross a Rotating Joint
Rotating transfers are usually split by what they carry, and most machines need more than one. Power goes through a slip ring, data through a ring or an optical joint, and air or fluid through a rotary union. The interfaces are often stacked on the same shaft, which is why the mechanical envelope, not the electrical rating, is frequently the limiting factor.
Contactless options change the maintenance picture. An inductive coupling removes brush wear and dust but loses efficiency across the gap and needs closer alignment. An optical joint passes a lot of data with no contact, at the cost of insertion loss and sensitivity to alignment. Where the axis turns only part of a revolution, a limited-sweep cable is still in the running, and it is usually the cheapest by a wide margin.
The Decision Table: Five Transfers and What Each One Costs
| Transfer | What It Carries | What to Specify | Evidence to Demand | Where It Fails in Service |
|---|---|---|---|---|
| Contact slip ring | Power and low-rate signal | Number of circuits, current per circuit, speed and noise limit | A life test at the working speed with contact resistance logged | Brush wear, conductive dust and rising electrical noise |
| Fibre optic rotary joint | Data only | Bandwidth, insertion loss and alignment tolerance at speed | Insertion loss measured while turning | Loss that rises with misalignment and ends as a data dropout |
| Fluid rotary union | Air, water or hydraulic fluid | Pressure, flow, seal type and the maximum leak rate | A leak and flow test at the working pressure | Seal wear and a leak that grows with pressure and speed |
| Contactless coupling | Limited power and signal | Gap, power level, efficiency and heat at the limit of the gap | A coupling test at the worst alignment and full load | Efficiency loss and heat, worst at the edge of the tolerance |
| Limited-sweep cable | Power and signal over a partial turn | Sweep angle, which must stay under a full revolution, plus cycle count | A torsion or bend test at the sweep angle | Wind-up after repeated sweeps that were meant to stay partial |
Choosing the Circuits and the Seals
The first specification is a circuit list rather than a part number. Count the power circuits and the current each one has to carry, then do the same for the signals, separating fast data from slow sensing, because the two have very different noise tolerances and are often better served on different paths. Air and fluid lines are counted the same way, with their pressure and flow, and stacked on the same shaft wherever the envelope allows.
The second specification is the seal and brush arrangement, because that is where the maintenance interval comes from. A contact ring wears and produces conductive dust, so it needs an interval and often a filtered enclosure around it. A fluid union wears its seals, so it needs an interval that reflects pressure and speed rather than only elapsed time. Asking for both intervals as numbers, and for the parts that go with them, turns the transfer from a black box into something a maintenance plan can carry.
Signal quality is the third specification and the one most often left vague. A ring that is fine for power can be a poor path for a bus or an encoder line, because the sliding contact adds noise that a power circuit ignores. Where a fast data link has to cross a rotating joint, an optical or contactless path is often the better answer even at a higher cost. The behaviour of screened and moving cable near this kind of interference is set out in our note on EMC and grounding on moving cable.
What to Freeze Before the Order
| Item | What to State | Evidence to Attach | Cost of Leaving It Open |
|---|---|---|---|
| Circuit list | Every power, signal, data and fluid path, counted and rated separately | A circuit schedule for the transfer | A transfer that runs out of ways to pass a function added later |
| Current per circuit | The current each power circuit carries, with its duty cycle | A thermal or current rating at that duty | Overheating at the contact and accelerated brush wear |
| Signal type | Which circuits are fast data, which are slow sensing, and the noise limit | A noise or signal integrity figure for the data path | Data dropouts and a fault that looks like a control problem |
| Speed and duty | The rotation speed and how many hours the joint turns | A life test at that speed | A wear interval quoted for a slower or intermittent duty |
| Fluid specification | Medium, pressure, flow and the maximum leak rate | A leak and flow test at the working pressure | A union that weeps under pressure and drops parts |
| Envelope and stack | The shaft, bore and length available for all the transfers together | A layout drawing with every element on the same shaft | Elements that fit separately but not stacked |
| Maintenance interval | Replaceable parts, their intervals and the spares to hold | A parts list with the swap procedure | A wear part treated as permanent that stops the line |
| Sweep versus rotation | Whether the axis truly rotates or only sweeps, stated as an angle | A motion profile for the axis | Paying for a rotating transfer an axis did not need, or the reverse |
When a Slip Ring Is Not the Answer
Where the axis only sweeps. A torsion rated cable is cheaper, smaller and has no wear parts, and it is the right answer whenever the axis stays within a limited angle. Buying a slip ring for a partial turn adds brushes, dust and a maintenance interval for no reason.
Where the signal is fast and the noise budget is tight. A sliding contact is a noisy path, and routing a high-rate link through one is a common source of data faults. Where the data matters, an optical or contactless path, or a separate route, is usually the better purchase even at a higher price.
Where nobody will maintain it. A slip ring produces wear debris and a union wears its seals, and both need an interval. If the machine is expected to run for years with no planned attention to the rotating joint, the transfer will fail on its own schedule rather than the maintenance one.
Where the envelope was not checked as a stack. Power, data and fluid transfers usually share one shaft, and each one fits on its own while the stack does not. Where the layout is tight, the mechanical envelope decides the purchase, and a smaller transfer with fewer circuits may be the only one that fits. Where the axis rotates while the cable also has to move elsewhere, the wider picture is the subject of our note on torsion cable in rotating applications.
RFQ Checklist
- Circuit list with every power, signal, data and fluid path counted and rated separately
- Current per power circuit stated with its duty cycle, not a single total
- Fast data and slow sensing listed as separate paths with their own noise limits
- Rotation speed and turning hours stated, so a wear interval can be quoted
- Fluid medium, pressure, flow and maximum leak rate given as numbers
- Shaft, bore and stack length shown on one layout drawing covering all the transfers
- Maintenance interval and spares named for the wear parts of each transfer
- Sweep angle stated, so a cable route can be compared against a rotating transfer
- Signal integrity evidence requested for any data path that crosses a contact
- Short fixed cables at each side of the transfer specified as part of the same order
Conclusion
A rotating transfer is the point where cable design stops and joint design begins, and it is chosen on the circuit list rather than on a part number. Count what has to cross, separate fast data from slow sensing, work out the envelope as a stack rather than element by element, and buy the maintenance interval along with the part. Where the axis only sweeps, a torsion rated cable is still the cheaper and simpler answer.
Kexingyu Cable Group (KXYE) supplies the short fixed cables that sit on each side of a rotating transfer: continuous flex and torsion rated constructions, including the robot composite cable, built to hold their geometry in the small space that remains around a slip ring stack. Send us the circuit list, the stack layout and the axis motion, and we will return constructions and sample lengths that fit; the fastest route is a request for quotation.


